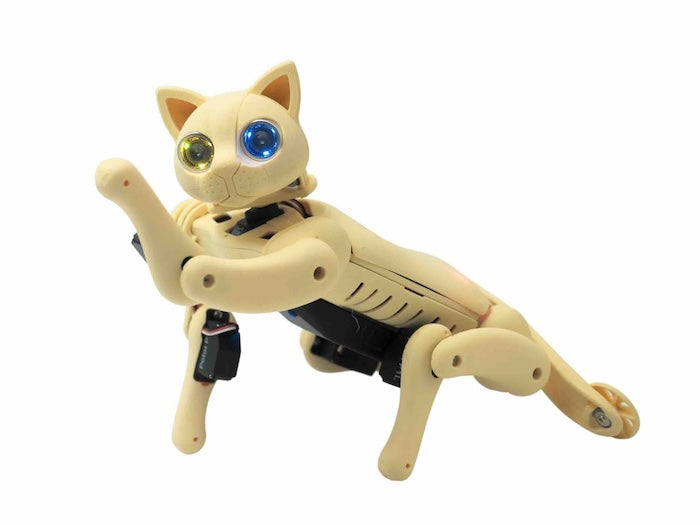
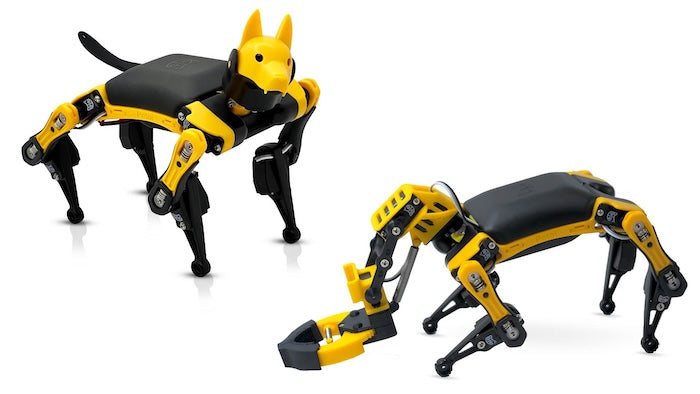
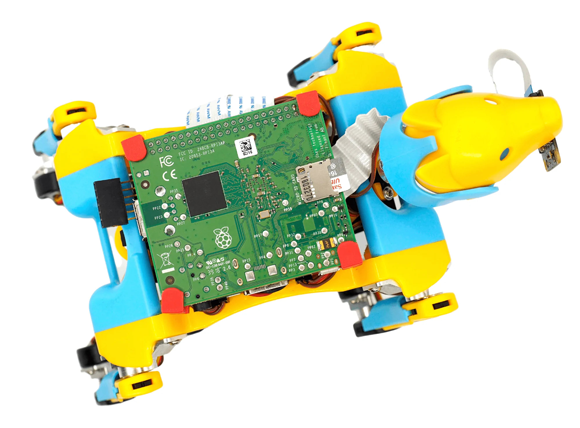
| Microcontroller Architecture | ESP32 BiBoard (240 MHz Dual-Core, 520 KB SRAM) | ESP32 BiBoard (240 MHz Dual-Core, 520 KB SRAM) | Proprietary 8-bit / Mask ROM ASIC |
| Source Code Accessibility | 100% Open Source (Firmware, Kinematics, Python SDK) | 100% Open Source (Firmware, Voice Stacks, Python SDK) | Closed Binary; Zero Firmware Inspection |
| Degrees of Freedom (DOF) | 11 Servos (8 Leg Joints, 2 Head/Neck, 1 Tail) | 9 Servos (8 Leg Joints, 1 Neck) + Robotic Arm | 4 to 8 Low-Precision Linkage Servos |
| Onboard Perception | 6-Axis IMU (MPU6050), Ultrasonic, Optional AI Vision | 6-Axis IMU, Voice Command Module, Optional AI Vision | Basic Infrared Collision Bumpers |
| SBC Co-Processor Support | UART/Serial mounting for Raspberry Pi Zero / 3A+ | UART/Serial mounting for Raspberry Pi Zero / 3A+ | Unsupported (No External Bus) |
| Programming Environments | Petoi Desktop App, Scratch Block Coding, C++, Python | Petoi Desktop App, Scratch Block Coding, C++, Python | Locked proprietary smartphone app only |
| Power Delivery System | 7.4V Li-ion Rechargeable Quick-Swap Smart Battery Pack | 7.4V Li-ion Rechargeable Quick-Swap Smart Battery Pack | Alkaline Non-Rechargeable or Pouch Cells |
| Academic Curricula Available | Structured Secondary & University Kinematics Labs | K-12 to Collegiate Embedded Programming Courses | None (Pure Consumer Toy) |