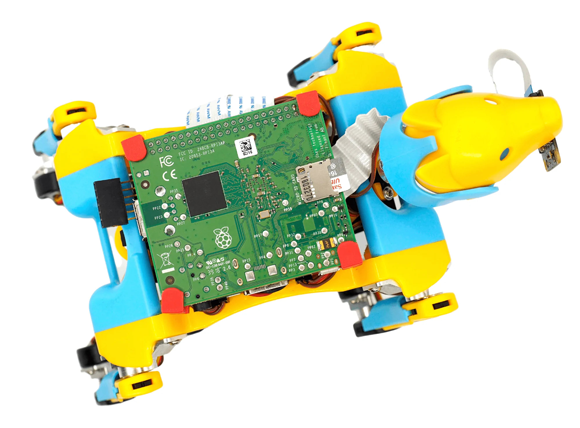
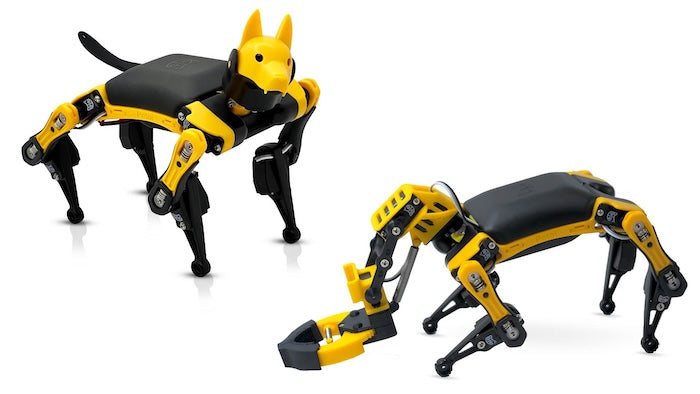
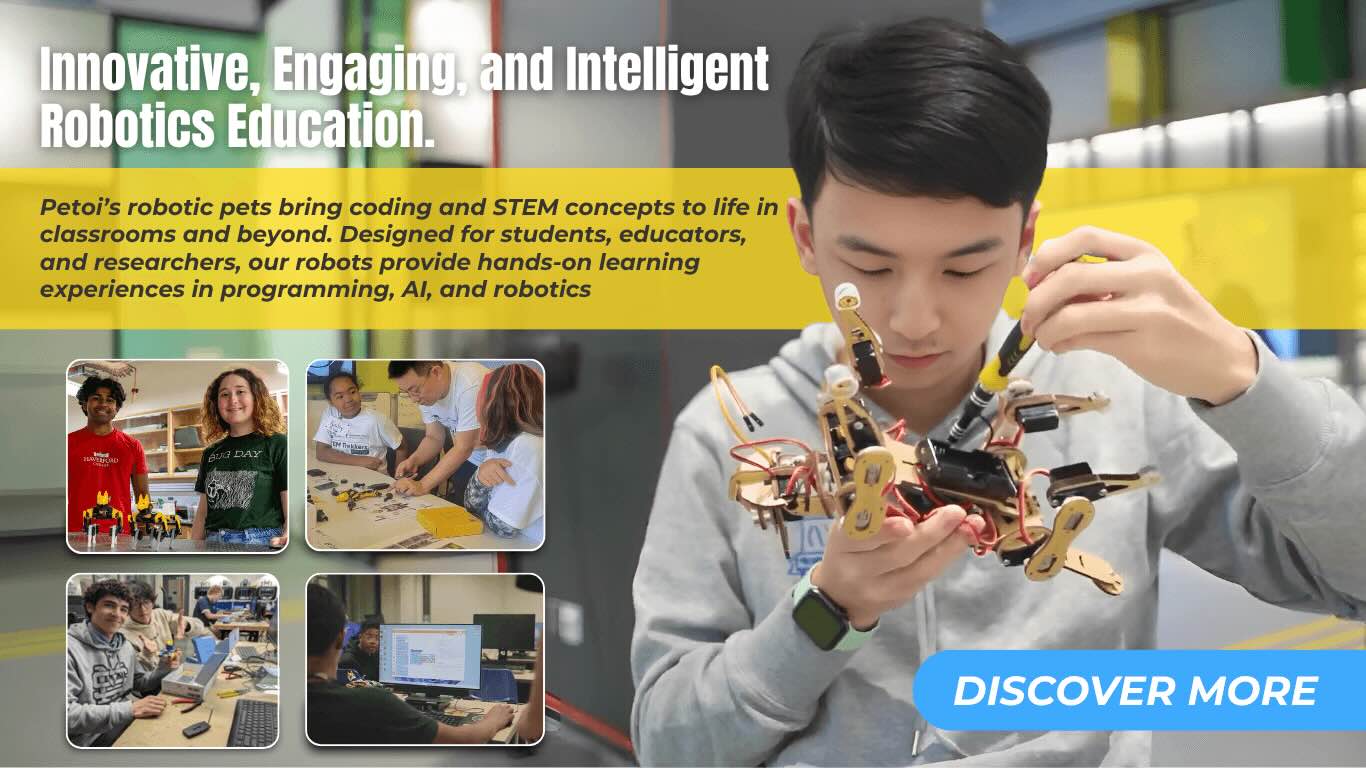
Bittle X Articulated Robotic Arm Gripper Extension
Engineered specifically for the Bittle X voice-controlled quadruped. Features multi-axis articulation, parallel claw kinematics, and direct BiBoard bus integration.
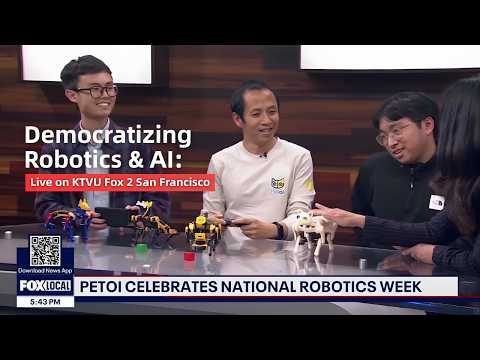
Trusted By Researchers & Featured In Global Tech Media
Global robotics procurement teams are rapidly transitioning from static inspection rovers to agile mobile manipulation systems capable of physical environmental interaction.
When autonomous quadrupeds and desktop rovers attempt mobile manipulation, standard industrial robotic arms fail due to excessive deadweight and power draw.
In classical robotics, mounting an end-effector arm onto a legged robot introduces sudden center-of-mass perturbations. Every centimeter of arm displacement alters the ground reaction force (GRF) across all four limbs. At Shenzhen Pbrobot Technology Co., Ltd., our proprietary engineering co-designs the robotic arm gripper extension with our open-source OpenCat framework. By synchronizing real-time inverse kinematics (IK) calculation across the ESP32 BiBoard and servo actuators, our gripper extension operates as an organic extension of the quadruped body rather than a detached accessory.
Integrated Kinematic Bus Field-proven hardware assemblies designed for secondary education, collegiate research, and commercial robotics integrators.
Engineered specifically for the Bittle X voice-controlled quadruped. Features multi-axis articulation, parallel claw kinematics, and direct BiBoard bus integration.
Combines a lightweight parallel robotic claw with an intelligent RGB edge vision camera module. Ideal for autonomous color sorting, AprilTag identification, and machine vision labs.
Versatile open-frame gripper extension module optimized for desk-sized quadrupeds and fixed robotic workcells. Complete with open CAD step files and custom servo mounting brackets.
In-depth hardware, electrical, and control benchmarks for institutional procurement officers and engineering leads.
| Parameter | Articulated Quadruped Arm Gripper | AI-Vision Visual Servoing Gripper | Desktop Open-Modular Gripper |
|---|---|---|---|
| Degrees of Freedom (DoF) | 2-Axis Motion + 1-Axis Clamping Claw | 1-Axis Pitch + 1-Axis Gripping + Camera Mount | Modular 1 to 3 DoF User-Configurable |
| Actuator Specifications | Digital coreless metal-gear servos (9g class) | Precision digital servos with anti-stall clutch | Standard 9g-12g metal/nylon gear compatibility |
| Gripper Clamping Range | 0 mm – 48 mm adjustable parallel span | 5 mm – 42 mm with rubberized non-slip pads | 10 mm – 60 mm (interchangeable finger geometry) |
| Net Mechanical Weight | ~90 g (minimizing torso momentum drift) | ~115 g (including camera sensor & bracket) | ~75 g (ultralight reinforced nylon polymer) |
| Operating Voltage | 6.0V – 8.4V regulated dual-cell Li-ion | 5.0V – 7.4V isolated logic and power rails | 4.8V – 6.0V standard micro-controller bus |
| Bus Communication | High-speed UART / Standard 2.54mm PWM | I2C / UART / USB Serial via Host SBC | Standard GPIO PWM / I2C servo driver |
| Software SDKs | Block coding, OpenCat C++, Python API | OpenCV, ROS/ROS2, Python, C++ | Arduino IDE, ESP-IDF, Python, Mind+ |
| Target Application | Classroom STEM, dynamic mobile delivery, games | Collegiate AI research, AprilTag sorting, SLAM | Makerspaces, mechanical thesis, custom robotics |
*All units manufactured by Shenzhen Pbrobot Technology Co., Ltd. are certified for FCC, CE, and RoHS standards. Tailored servo torques available upon bulk inquiry.
How artificial intelligence, material sciences, and open architectures are redefining the global procurement of robotic arm gripper extensions.
Global universities and research centers are no longer buying passive grippers. The shift is decisively toward end-effectors equipped with edge vision cameras capable of onboard inferencing. Future-proof procurement requires direct serial passthrough to Raspberry Pi, Jetson Nano, or Hailo edge accelerators for multimodal physical AI.
Traditional aluminum arms severely limit mobile robot operation time. Procurement departments are demanding high-impact modified PA12 and carbon-infused composites that slash end-effector mass by over 40% while preserving torsional rigidity and high clamping forces under continuous cyclic loads.
Educational institutions and robotics consortia actively reject proprietary, closed-source ecosystems. The future procurement standard centers around cross-compatible frameworks—like OpenCat—that let researchers inspect source code in C++, build custom ROS2 nodes, and script tasks in Python without recurring license fees.
Traditional analog PWM is rapidly giving way to half-duplex daisy-chained serial bus servos. Procurement managers are prioritizing arms offering angle readback, temperature monitoring, and overload protection to prevent field burnout and facilitate machine learning reinforcement training.
From egg-grasping challenges to fragile micro-electronic handling, mechanical rigid jaws are being augmented with silicone compliance caps and fin-ray effect flexural members. Purchasing departments favor systems offering modular, swappable fingers for rapid application switching.
B2B school distributors and STEM franchise buyers now demand complete turnkey instructional assets. Hardware procurement is directly tied to the availability of structured, standards-aligned learning paths bridging visual block coding to real-world embedded robotics.
Discover how Shenzhen Pbrobot Technology Co., Ltd. leads technical advancements in biomimetic mobile manipulation.
Higher Ed Lab Proven We are pioneering the synthesis of physical manipulator mechanics with cloud simulation engines like Isaac Sim, MuJoCo, and Gazebo.
Our upcoming engineering milestones focus on enabling seamless digital twin simulations where quadrupeds equipped with robotic arm gripper extensions learn grasping trajectories in simulated physics before executing with millimeter accuracy on real physical hardware. By maintaining tight tolerances across our high-torque digital servos and minimizing joint backlash, our assemblies provide the repeatability demanded by modern reinforcement learning algorithms.
Furthermore, our multi-agent swarming protocols enable coordinated cooperative lifting where two or more Bittle X units collaborate on payloads exceeding single-unit thresholds—demonstrating real-world industrial swarm concepts at a fraction of standard CAPEX.
As the creators of the world's most popular open-source quadruped architecture, we combine cutting-edge bionic engineering with scalable manufacturing reliability for schools, universities, and commercial partners worldwide.
Direct technical and operational answers to the most common queries submitted by global procurement teams and institutional researchers.
When an articulated arm moves forward to grasp an object, the robot's dynamic center of gravity (CoG) shifts forward and downward. In traditional hobbyist kits, this causes pitch destabilization or leg servo stall.
Our solutions overcome this through our specialized OpenCat kinematic co-processor algorithms running on the ESP32 BiBoard. The controller continuously computes pitch-axis compensation and redistributes stance loads across the fore and hind legs. As a result, the quadruped can execute walking, turning, sitting, and recovery routines smoothly while holding objects up to its maximum rated capacity.
The robotic arm gripper extension integrates directly with standard 2.54mm pitch headers on our BiBoard (ESP32) and NyBoard (Arduino) microcontrollers. For advanced AI computing, it communicates seamlessly over high-speed hardware UART or USB-serial.
Supported host processors include Raspberry Pi 3A+, Raspberry Pi 4B, Raspberry Pi Zero 2W, and NVIDIA Jetson Nano. We provide pre-built open-source Python wrapper libraries and ROS/ROS2 node templates, allowing engineers to send high-level trajectory commands directly from computer vision or machine learning scripts.
Absolutely. Accessibility across pedagogical tiers is a core tenet of our design philosophy:
• Primary & Middle School: Visual block-based coding (Petoi Coding Blocks, Mind+, Scratch-compatible) allows learners to assemble pick-and-place logic visually without syntax errors.
• High School & Undergraduate: Arduino IDE (C++) enables direct register manipulation, custom servo angle control, and inverse kinematic trajectory coding.
• Graduate & Commercial R&D: Python SDK and ROS integrations support visual servoing, AprilTag tracking, obstacle avoidance, and SLAM mapping.
The entire arm and gripper assembly weighs approximately 90 grams. Driven by coreless digital metal-gear servos operating at up to 8.4V, the gripper delivers a static holding force of over 4.5 N and a dynamic manipulation payload of up to 150 grams on flat terrain.
This capacity allows mobile quadrupeds like Bittle X to securely pick up, transport, and deliver items such as laboratory reagent vials, standard testing blocks, ping-pong balls, keys, and custom 3D-printed tools.
Shenzhen Pbrobot Technology Co., Ltd. supports orders of all scales:
• Standard Lab Bundles: MOQ starts at 5 units for institutional evaluation packs.
• Classroom & Distributor Sets: Full classroom packs (10–50+ units) typically ship within 5 to 7 business days from our Shenzhen manufacturing facility.
• OEM / ODM Customization: For orders over 500 units, we offer custom-branded injection molding colors, laser engraving, pre-flashed custom firmware, and specialized servo bracket engineering.
All hardware is backed by our standard 1-year manufacturing warranty and rigorous quality inspection protocols. Because we control the original OpenCat hardware design, we guarantee component and replacement part availability (including servo packs, gearboxes, linkage pins, and controller boards) for a minimum of 5 years, protecting your institutional capital investment.
For technical inquiries, warranty support, and institutional purchase orders, contact our dedicated engineering team at [email protected].
Watch how integrating a robotic arm gripper extension transforms abstract physics, kinematics, and coding into tangible, engaging student mastery.
"Giving the robot an arm and gripper fundamentally changes student engagement. They aren't just writing code to make a robot walk; they are solving spatial manipulation problems and designing pick-and-place routines." — STEM Faculty, CU Boulder
Request the complete 2026 Institutional Hardware Catalog, complete with parametric CAD files, sample robotics curricula, and bulk pricing schedules from Shenzhen Pbrobot Technology Co., Ltd.
[email protected]