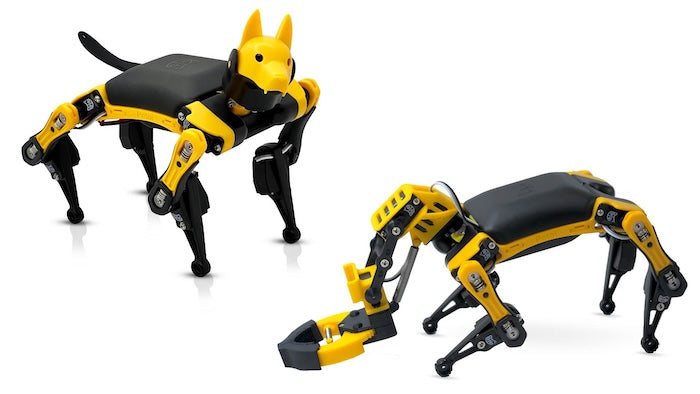
Bittle X Robot Dog V2
High-agility quadruped with built-in voice commands, Bluetooth/Wi-Fi, and 9 high-precision servos.
ESP32 BiBoardVoice CommandIMU Gyro
Developed by Shenzhen Pbrobot Technology Co., Ltd., this standards-aligned C++ syllabus bridges theoretical coding concepts with tangible bionic hardware, empowering instructors to launch authentic quadruped robotics courses without licensing barriers.
Master syntax fundamentals, pointers, object-oriented libraries, and real-time microcontroller control directly within standard Arduino and ESP32 programming environments.
Move beyond 2WD/4WD wheeled chassis. Students calculate center-of-gravity compensation, servo joint angles, and dynamic rhythmic gaits on genuine legged robots.
Includes instructor presentation decks, reproducible student lab workbooks, code challenge templates, and rubric assessments formatted for secondary and collegiate programs.
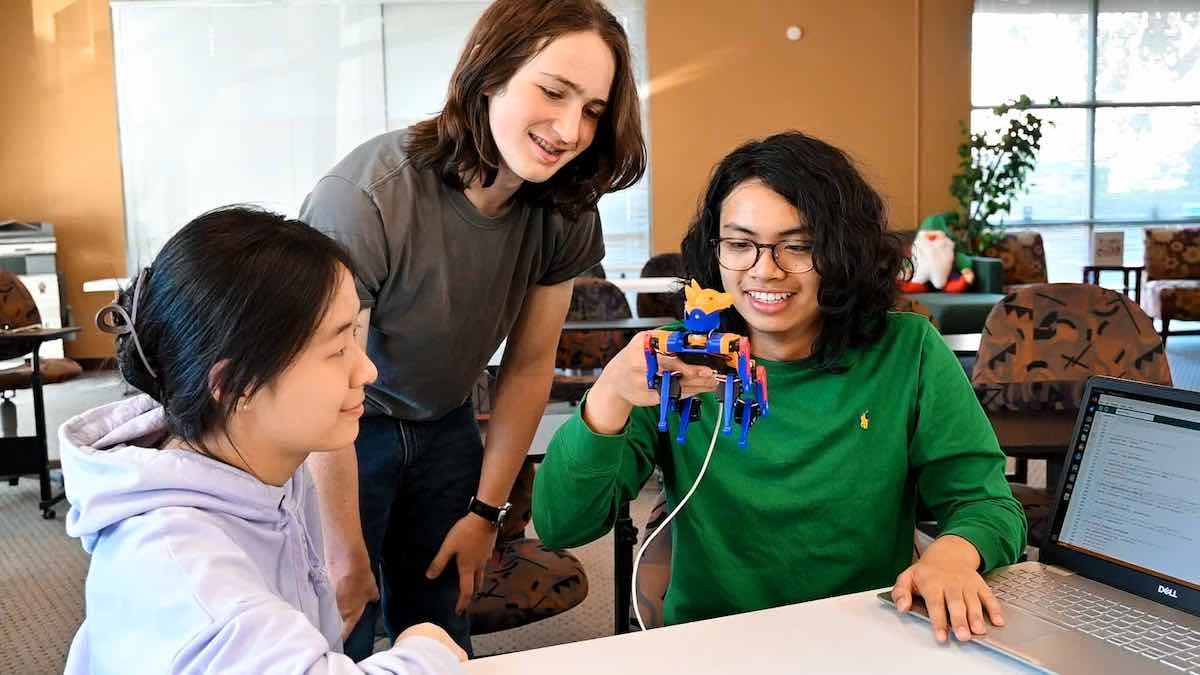 High School to Undergraduate Ready
Wheeled mobile platforms often reduce student coding exercises to simple forward-backward delays. Quadruped biomimetics challenge students to solve multi-axis coordinate math and joint sequencing in physical space.
Every module is structured with theoretical concepts, live coding walkthroughs, guided laboratory exercises, and open-ended engineering design challenges.
| Unit | Core Topic | Learning Objectives & Technical Scope | Laboratory Exercise |
|---|---|---|---|
| Unit 1 | Arduino IDE & Board Configuration | Setting up the Arduino development environment, installing board managers, configuring drivers, and flashing firmware to the NyBoard/BiBoard controller. | Blink & Diagnostic Test |
| Unit 2 | Digital I/O & Acoustic Output | Understanding digital pin addressing, pull-up resistors, pulse-width tone generation, and buzzer sound synthesizers. | Expressive Audio Alerts |
| Unit 3 | C++ Variables & Arithmetic Logic | Declaring integers, floating points, booleans, and string objects; calculating sensor offsets and kinematic time constants. | Dynamic Parameter Calc |
| Unit 4 | Conditional Decision Trees | Mastering if-else logic, switch-case constructs, relational comparisons, and responsive behavioral branch control. | Tactile Reflex Triggers |
| Unit 5 | Loops & Iterative Sequencing | Using for and while loops to iterate joint angles, manage multi-servo synchronization, and smooth motion interpolation curves. | Gait Cycle Generation |
| Unit 6 | Arrays & Posture Look-Up Tables | Storing 9-axis joint coordinates in multi-dimensional arrays; indexing frame-by-frame poses for biomimetic behavior. | Custom Pose Matrix |
| Unit 7 | Modular Function Architecture | Refactoring code into modular C++ functions with arguments and return values; organizing clean, reusable embedded libraries. | Behavioral Skill Library |
| Unit 8 | Analog Sensing & Environmental Input | Reading analog voltage dividers, ambient light sensors, and calibration curves to react to illumination gradients. | Phototaxis Light Follower |
| Unit 9 | Ultrasonic Distance & Spatial Navigation | Measuring echo time-of-flight, calculating obstacle distance in centimeters, and programming reactive collision avoidance algorithms. | Autonomous Room Patrol |
| Unit 10 | PIR Motion & Security Systems | Interfacing passive infrared thermal sensors, digital edge detection, and intruder response protocols. | Autonomous Guard Dog |
| Unit 11 | Advanced Kinematics & Balance Control | Utilizing onboard 6-axis IMU gyroscopes/accelerometers for dynamic posture leveling on uneven inclines. | Self-Righting & Balance |
| Unit 12 | Capstone Multi-Sensor Robotics Project | Synthesizing voice recognition, robotic arm gripping, vision tracking, and autonomous gait generation into an integrated system. | Search & Retrieve Mission |
Engineered by Shenzhen Pbrobot Technology Co., Ltd., each kit is manufactured with shock-resistant ABS components, metal-gear servos, and open-source electronics designed for rigorous classroom and lab turnover.
High-agility quadruped with built-in voice commands, Bluetooth/Wi-Fi, and 9 high-precision servos.
The original Arduino-compatible bionic quadruped robot kit trusted by universities and engineering camps.
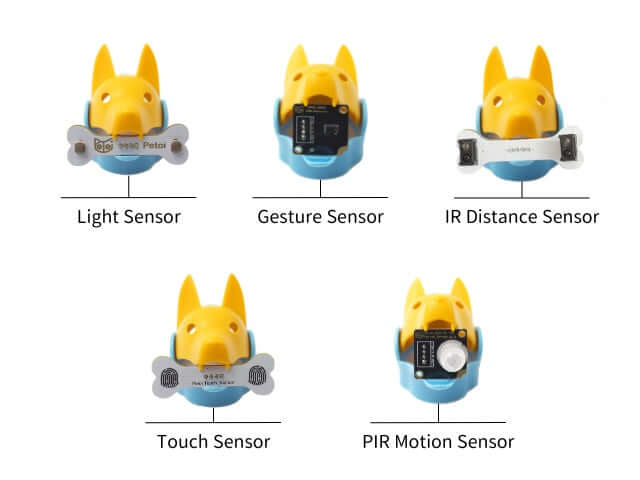
Set of 5 plug-and-play Grove sensor modules: Light, Touch, Gesture, PIR Motion, and Distance sensors.
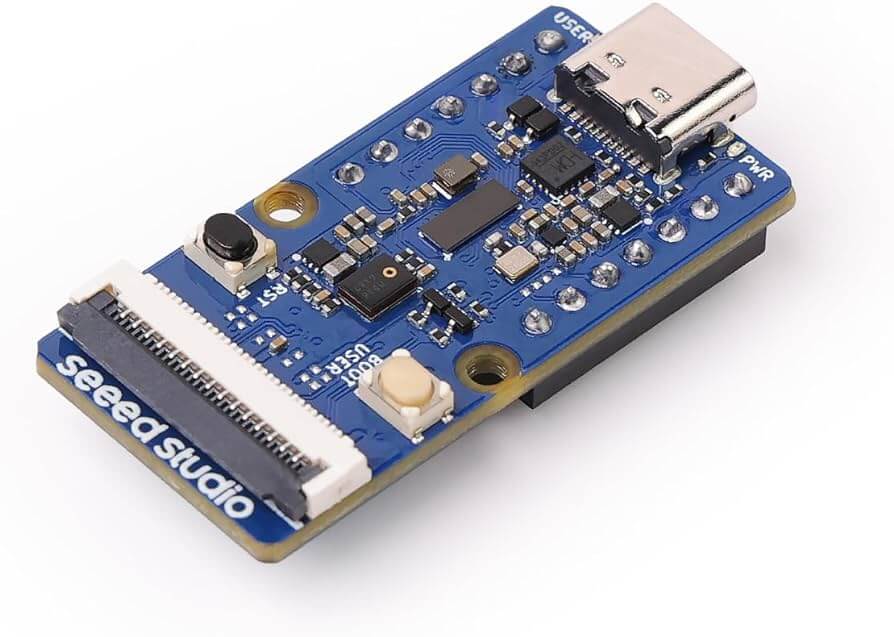
Onboard edge AI camera capable of body tracking, face detection, gesture tracking, and 80-class object identification.
Shenzhen Pbrobot Technology Co., Ltd. partners with academic institutions, regional educational ministries, and robotics training franchises to deliver standardized, high-reliability robotics lab deployments.
Key information regarding hardware specs, software prerequisites, and institutional procurement policies.
The curriculum is optimized for Shenzhen Pbrobot Technology Co., Ltd.'s Bittle and Bittle X open-source quadruped robots, paired with standard Arduino Uno/ESP32 compatible control boards, standard mini USB programming cables, and optional sensor expansion modules such as ultrasonic, PIR, light, and AI vision cameras.
Students should possess foundational familiarity with basic computer operations and introductory logic concepts. While prior exposure to Scratch or block coding is helpful, the curriculum begins with foundational C++ syntax, variable declaration, control structures, and Arduino IDE library management before advancing to robotics locomotion.
Yes. Shenzhen Pbrobot Technology Co., Ltd. provides full instructor slide decks, detailed syllabi, step-by-step student lab workbooks, assessment rubrics, and open-source GitHub code repositories free of software licensing fees.
Yes. Educational institutions, universities, STEM makerspaces, and regional procurement distributors can submit inquiries directly to [email protected] to obtain institutional quantity discounts, customized hardware-curriculum bundles, and international shipping arrangements.
Contact our STEM education consultants to receive complete syllabus bundles, evaluation units, and tailored volume proposals for your academic department or distribution territory.
[email protected]