Five Integrated Subsystems Engineered for Bionic Mobility
To balance cutting-edge legged maneuverability with commercial affordability and mass manufacturability, our quadruped platform is built around five modular, tightly coupled hardware and software pillars.
Biomimetic Body Frame
Interlocking snap-fit symmetric puzzle structures engineered for high impact damping, minimal fastener usage, and DIY serviceability.
Digital Actuators
Custom-tuned high-torque coreless/brushed digital servos offering wide 270° angle control, fast response, and custom PID stability.
Embedded Electronics
Arduino NyBoard V1 and 32-bit ESP32 BiBoard architectures integrated with 6-DOF IMU for active balance and high-speed multi-channel PWM control.
OpenCat Software
Lightweight, real-time kinematic gait algorithms, visual Skill Composer, and comprehensive SDKs across Scratch, C++, and Python.
Smart Power Module
Slide-in Li-ion smart battery packs with integrated protection circuits, tunable center-of-gravity rail tracks, and continuous high-discharge output.
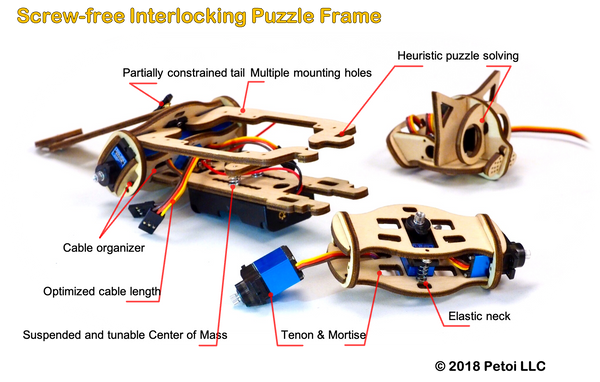
Symmetric interlocking puzzle components engineered for tool-light assembly
Symmetric Interlocking Frame & Bio-Inspired Structure
Unlike rigid metal chassis that transfer impact forces directly to servo drive gears, our quadruped bodies utilize lightweight, interlocking modular puzzle components with elastic shock dissipation.
- High Crash Resilience: Engineered flexibility enables automatic self-righting after roll-overs or slope falls.
- Minimal Fasteners: Symmetric components snap together securely, cutting assembly and field replacement times.
- Clip-on Mount Geometry: Head and back geometries feature integrated clip sockets to mount sensory payloads, cameras, or grabbers.
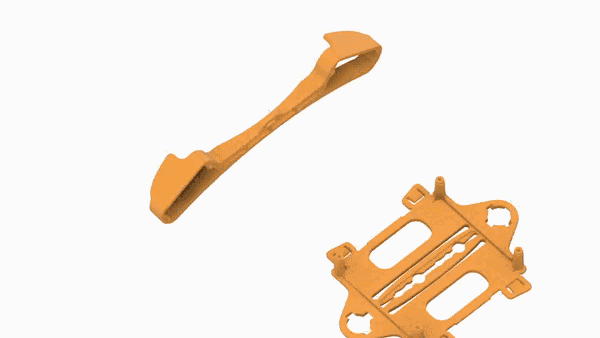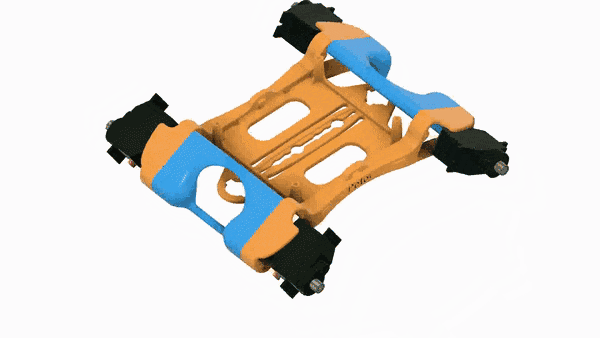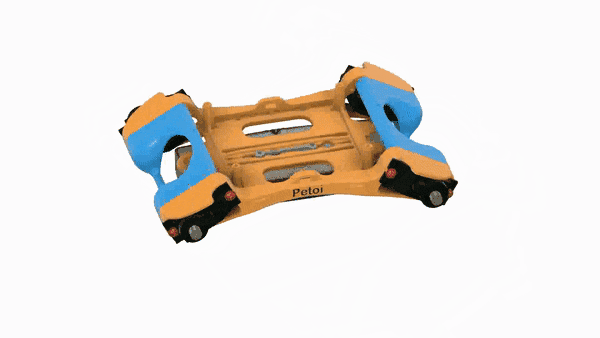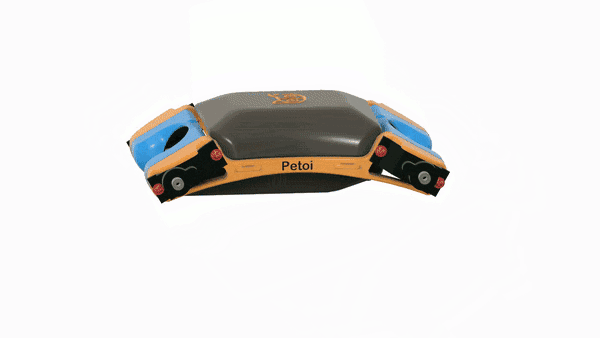
Rapid mechanical assembly workflow built for classroom labs and makers
Precision Digital Servos with Customized PID Control
Legged kinematics require actuators capable of holding stable static postures while executing rapid dynamic phase transitions without angular drift.
We co-engineered our proprietary P1S digital servo series specifically for high-frequency legged locomotion:
- 270° Controllable Range: Wider operational envelope allows extreme lifelike animal postures and full recovery sequences.
- Kinematic Tuning: Internal PID loops are calibrated to prevent mechanical resonance across trotting, crawling, and leaping gaits.
- Dual Bearing Reducer: High-efficiency gearboxes ensure long lifespan under repeated classroom or laboratory duty cycles.

NyBoard V1 controller featuring high-channel PWM, IMU sensor, and Grove interfaces
NyBoard V1 & ESP32 BiBoard Architectures
Our controllers integrate multi-servo synchronization, IMU feedback, muscle-memory EEPROM storage, and high-level communications onto a single compact PCB.
Whether choosing the battle-tested Arduino-compatible NyBoard or the high-throughput dual-core ESP32 BiBoard, both architectures eliminate external driver boards:
- Integrated 6-Axis IMU: Continuous posture feedback enables automatic real-time dynamic balance compensation.
- Multi-Channel Servo Output: Drives at least 12 independent PWM lines directly with precision timing control.
- Plug-and-Play Expansion: Four Seeed Grove sockets accommodate environmental, acoustic, gesture, and distance sensors.
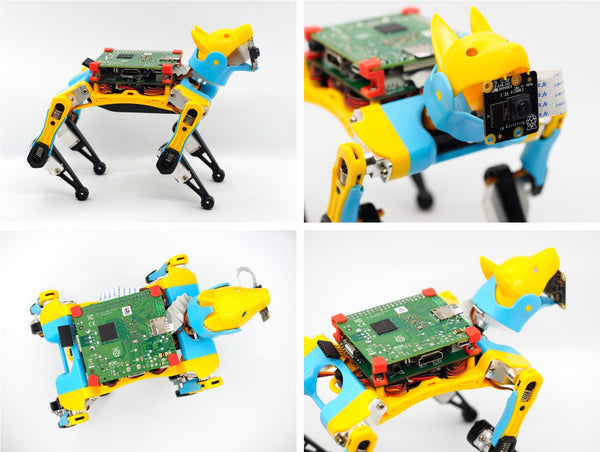
Compact single-board computer integration for onboard Edge AI, computer vision, and SLAM
Hierarchical Computing: Raspberry Pi & Edge AI Chips
By pairing the embedded motor controller with a high-level microprocessor, users establish an industrial-grade dual-tier compute pipeline: high-level perception driving real-time reflexive motion.
- Direct 2x5 Pin Header: Seamlessly powers and networks Raspberry Pi 3A+, Pi Zero 2W, or micro:bit via UART serial / I2C bus.
- Intelligent Vision Pipeline: Mount AI vision camera sensors to run color blob tracking, face detection, and ball tracking routines in real time.
- Remote Processing Support: Network Jetson Nano or cloud server compute over Bluetooth/Wi-Fi to execute heavy deep reinforcement learning algorithms.
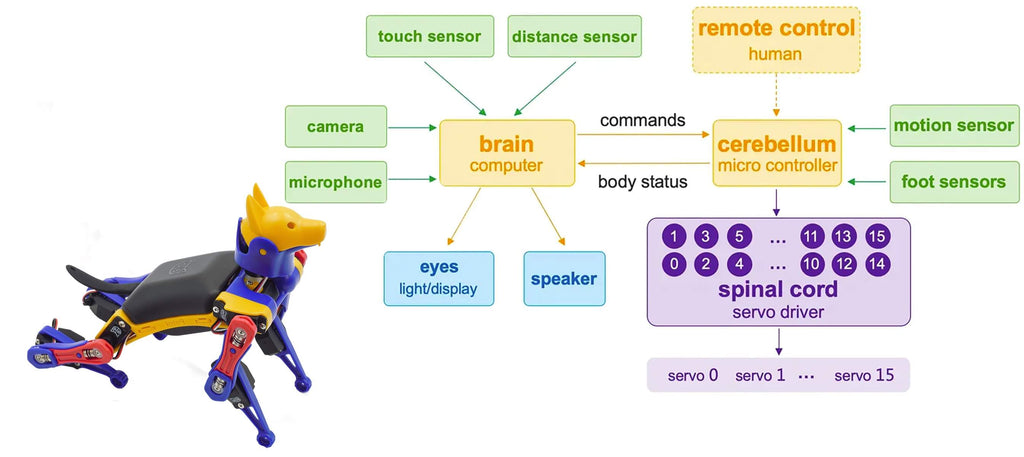
Multi-tier OpenCat programming stack spanning Scratch, C++, and Python
Open-Source Robotics Firmware & Multi-Tier SDKs
Built upon GitHub's most acclaimed quadruped robot framework (OpenCat), the platform abstracts complex inverse kinematics into straightforward movement arrays and serial command strings.
- Lightweight C++ Core: Around 3,000 lines of highly optimized C/C++ firmware handle gait interpolation without bulky overhead.
- Visual Skill Composer: A graphical calibration and joint keyframing utility allowing custom gait and trick creation without coding.
- Python Serial API: Fully documented
SerialMasterlibrary enables multi-platform teleoperation and autonomous scripting.
Slide-in Li-ion pack featuring onboard BMS protection and tunable rail balance
Custom Smart Li-ion Battery & Mass-Center Tuning
Stable quadruped dynamic locomotion is contingent upon an accurate center of gravity. Our custom-engineered power system serves as both energy storage and structural ballast.
- Tunable Sliding Rail: The battery slides along underside grooved tracks, letting operators shift center of mass when front-heavy AI cameras or mechanical arms are added.
- Integrated BMS Protection: Onboard circuit provides overcharge, over-discharge, and short-circuit protection for student safety.
- Runtime & Diagnostics: Delivers over 60 minutes of sustained continuous locomotion, featuring multi-color status LED indicators.
Controller & Architecture Specifications
Hardware specifications evaluated for institutional purchasers, academic laboratories, and international STEM distributors.
| Specification Parameter | NyBoard V1 (Classic Platform) | BiBoard Series (ESP32 Platform) |
|---|---|---|
| Microcontroller Core | ATmega328P @ 16 MHz (Arduino Uno Equivalent) | Dual-Core Tensilica Xtensa 32-bit LX6 / ESP32 |
| PWM Actuation Channels | 12 Dedicated High-Resolution Servo Channels | 12+ Configurable PWM Servo Channels |
| Inertial Measurement (IMU) | Onboard 6-DOF IMU (Accelerometer + Gyroscope) | Integrated 6-DOF IMU with Hardware Sensor Fusion |
| Wireless Connectivity | Via USB Bluetooth / Wi-Fi Adapter Modules | Native 2.4 GHz Wi-Fi & Bluetooth BLE 4.2 Onboard |
| SBC Co-Processor Port | Dedicated 2x5 Pin Socket (Serial UART / I2C) | High-Speed Serial Bus & I2C Communication |
| Sensor Peripheral Expansion | 4x 4-Pin Grove Compatible Connectors | Grove Interfaces & Multi-Purpose GPIO Headers |
| Supported Software Toolchains | Arduino IDE (C++), Petoi Coding Blocks, Python | Arduino IDE, ESP-IDF, Petoi App, Python Serial API |
| Primary Academic Use-Case | K-12 STEM Classes, Introductory Coding, Makers | University Research, Reinforcement Learning, Computer Vision |
Partner with Shenzhen Pbrobot Technology Co., Ltd.
Looking for curriculum-ready robotics kits for your educational institution or interested in expanding your distribution territory? Contact our engineering and commercial sales desk.
[email protected]