Official Visual Showcase

Robot Pet Gallery

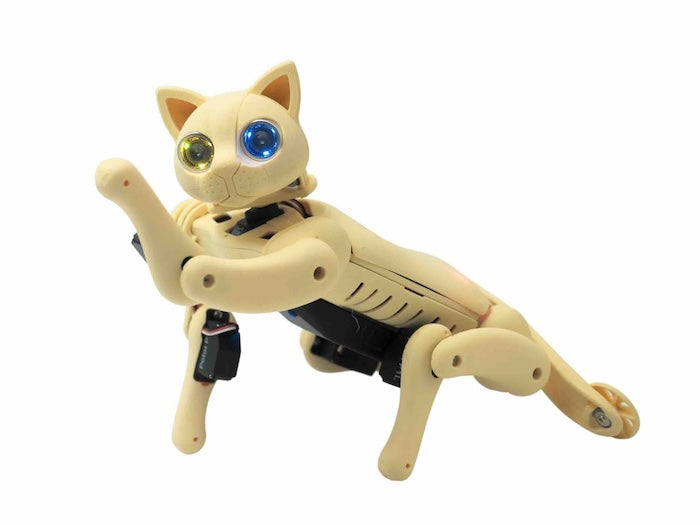
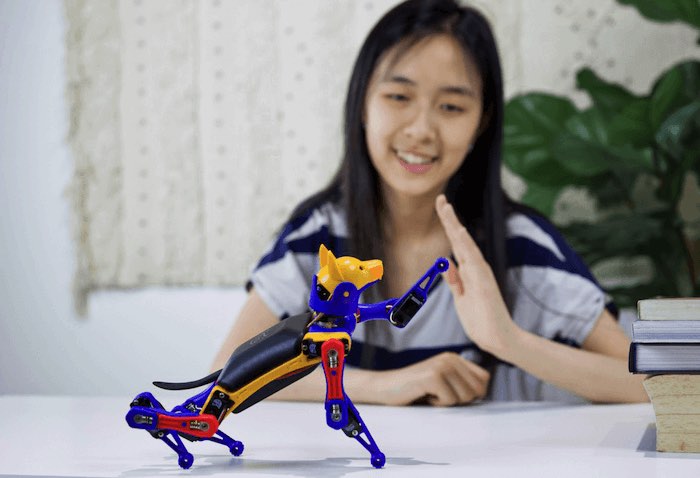
Discover real-world applications of Petoibittle open-source quadruped robots, bionic cat kits, and intelligent vision integrations deployed across global STEM programs and research laboratories.

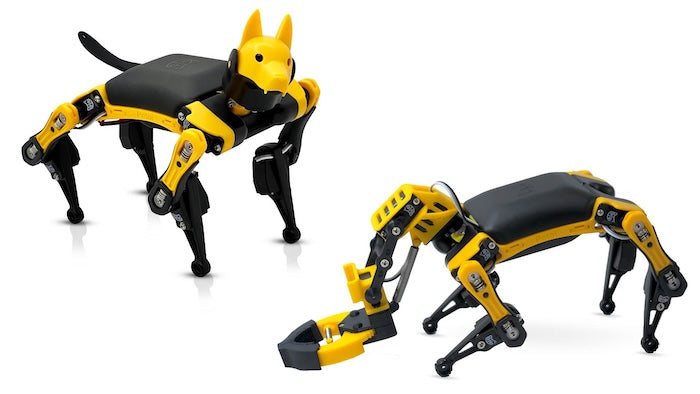
Quadruped robotics laboratory build session
Institutional Standards

Engineered for Repeated Classroom & Research Rigor

Petoibittle robotics platforms bridge the gap between simple toy-grade wheeled robots and costly industrial quadrupeds, providing universities, schools, and distributors with a robust, field-tested development foundation.

  • Open-Source Framework: Built upon OpenCat, the worldwide standard for miniature quadruped locomotion algorithms on GitHub.
  • Dual Controller Ecosystem: Supporting ESP32 BiBoard high-speed multi-threading and classic Arduino architecture with open I/O headers.
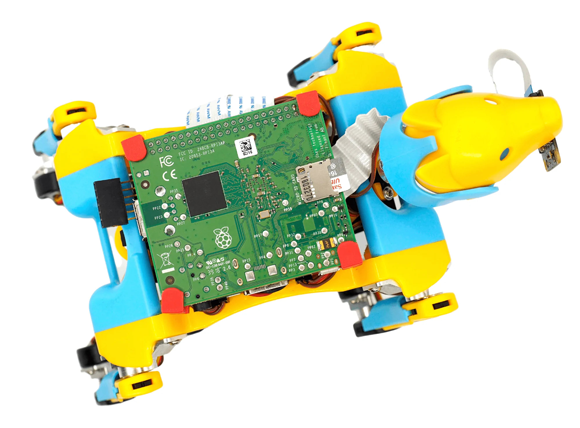
  • Extensible Payload: Direct serial UART support for Raspberry Pi Zero, 3A+, and NVIDIA Jetson Nano edge-AI processors.
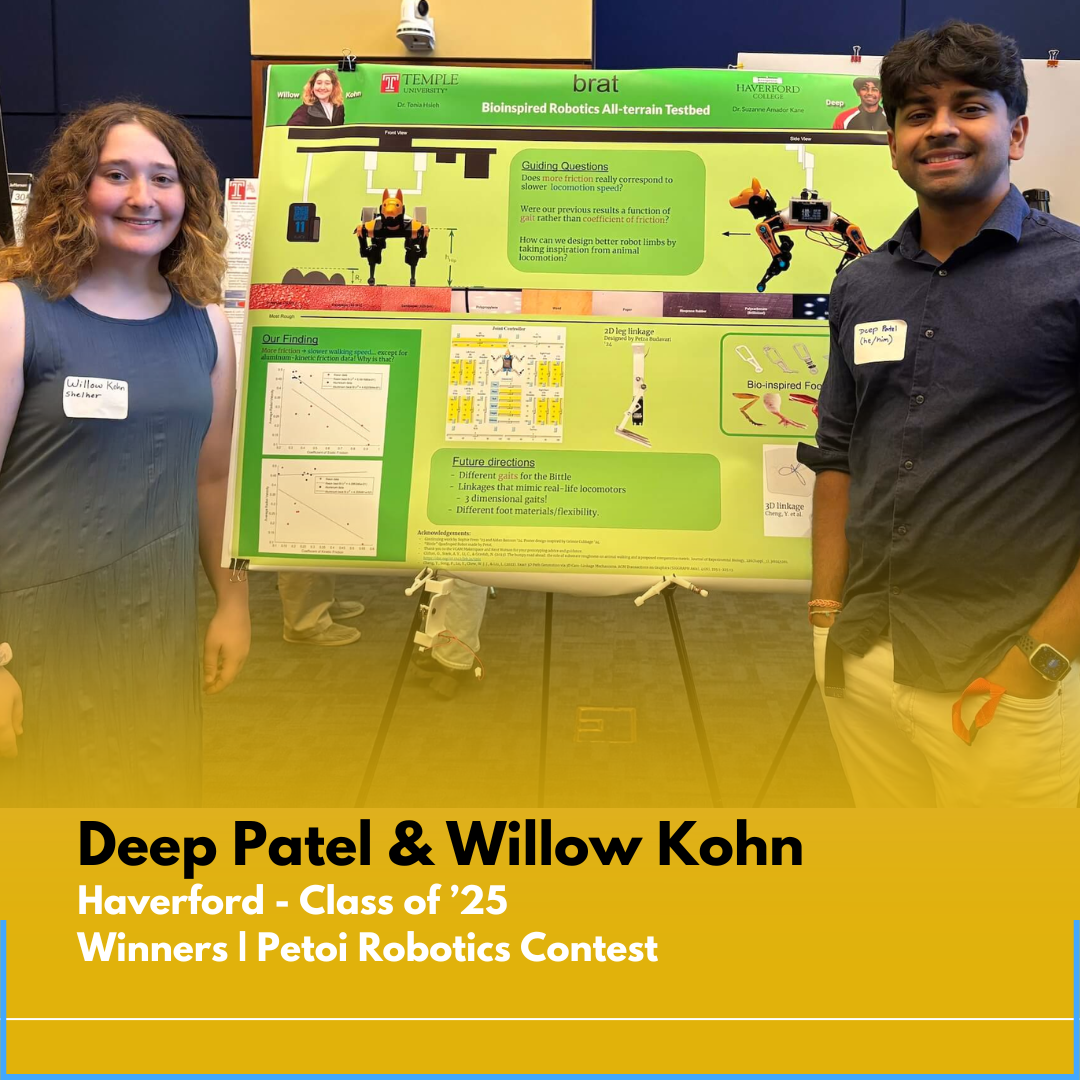
University robotics lab research group working with Petoibittle quadrupeds
Academic & Research Utilization

Autonomous Navigation & Kinematics Research

Institutions worldwide deploy Petoibittle quadrupeds to validate reinforcement learning models, spatial awareness routines, and cooperative robotic swarm maneuvers in compact, safe indoor testing environments.

  • Postural Balancing: Integrated 6-axis MPU IMU sensors deliver continuous dynamic balance correction and self-righting algorithms.
  • Visual Skill Composer: Create and calibrate custom locomotion gaits, interactive dance poses, and athletic tricks visually.
  • Multi-Language Code Stack: Smooth progression from Scratch block-based drag-and-drop to professional C++ firmware and Python scripting.
B2B Specifications

Built for Educational Tenders & International Distribution

Comprehensive procurement reliability criteria ensuring smooth adoption for schools, science centers, and robotics resellers.

Bulk Packaging & Class Packs

Custom packaging configurations, pre-assembled options, and bundled spares designed specifically for high-throughput semester lab rotations.

Complete Courseware Included

Zero syllabus prep required. Access fully structured, standards-aligned block-based coding and C++ quadrupeds teaching curricula at no royalty cost.

Reliable Global Fulfillment

Manufactured under strict ISO-grade QA protocols by Shenzhen Pbrobot Technology Co., Ltd. with door-to-door international logistics coverage.

Direct Engineering Support

Dedicated technical assistance for institutional buyers, including schematic access, firmware libraries, and parts replacement support.

Hardware Specifications for Engineering Evaluation
Evaluation Metric Bittle X V2 (Flagship) Nybble Q (Bionic Cat) Bittle Classic Quaddle (Desktop)
Microcontroller Core BiBoard (ESP32 Dual-Core 240MHz) BiBoard (ESP32 Dual-Core 240MHz) NyBoard V1 (ATmega328P 16MHz) Compact ESP32 Controller
Degree of Freedom (DoF) 9 (Legs + Neck) or 10 (+ Arm) 11 (Legs, Head, Tail) 9 (Legs + Neck) 8 (Leg Joints)
Servo Actuation Alloy-geared coreless servos Alloy-geared coreless servos Lite / Metal geared options Precision miniature servos
Native Communication Bluetooth 5.0, Wi-Fi, USB Serial Bluetooth 5.0, Wi-Fi, USB Serial USB Serial (Dongle for BT/WiFi) Bluetooth, Wi-Fi, USB-C
Voice Interaction Built-in speech recognition module Optional Grove Voice module Optional voice module Software-defined commands
Edge Computing Payload Raspberry Pi Zero/3A+, AI Vision External Vision, Grove sensors Raspberry Pi via UART Compact sensor extensions
Target Educational Tier High school, university, research STEM clubs, makers, competitions Entry Arduino STEM programs Maker desks, introductory robotics
#1 Starred Quadruped Platform on GitHub
100+ Universities & STEM Schools Deployed
50+ Countries with Active User Installations
100% Open-Source Hardware & Code Compatibility

Equip Your STEM Lab or Distribution Network

Connect with the engineering and procurement specialists at Shenzhen Pbrobot Technology Co., Ltd. for volume quotations, syllabus consultations, and tailored robotic platform configurations.