Quaddle Desktop Robot Kit
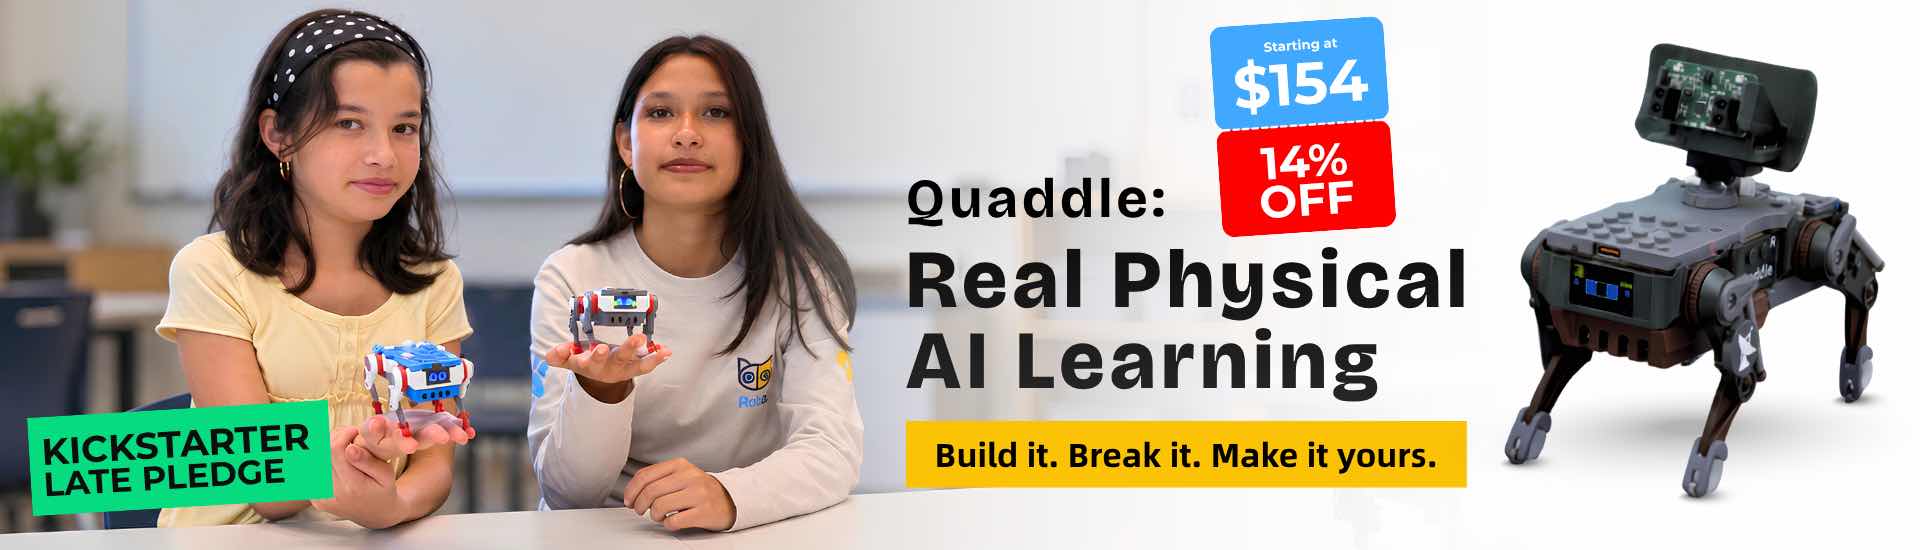
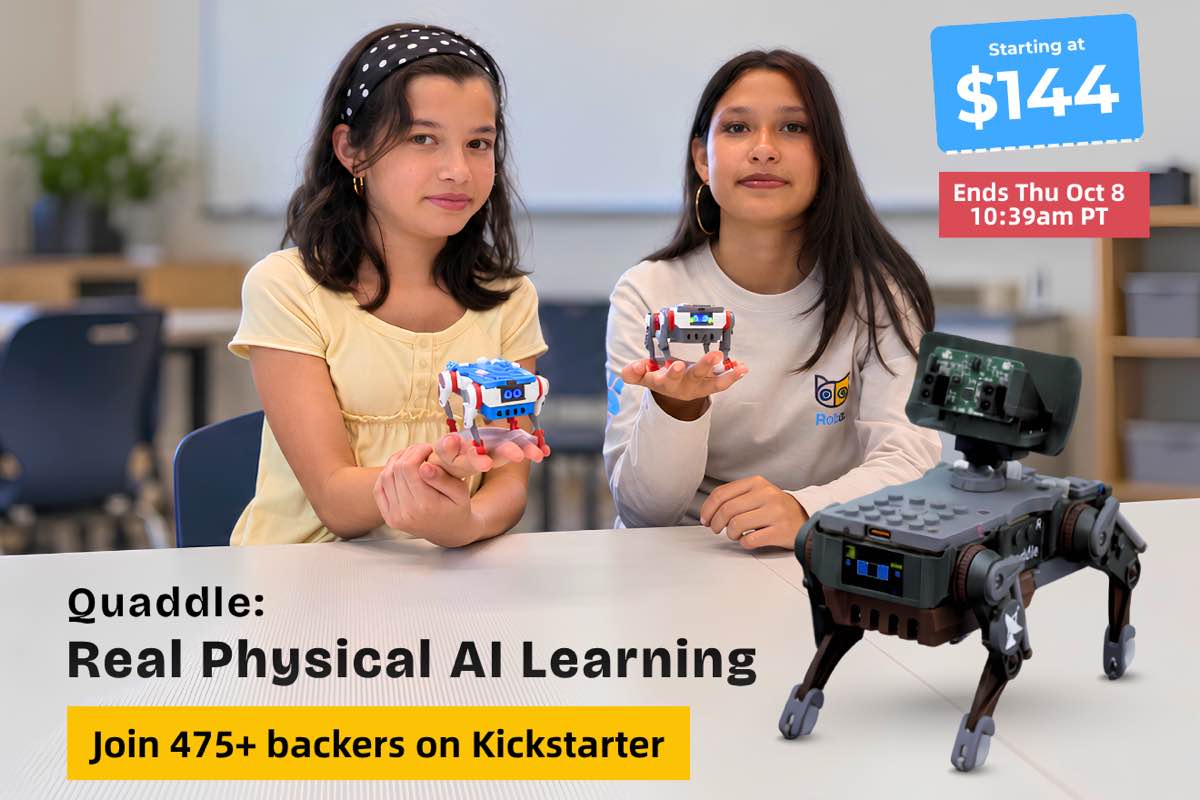
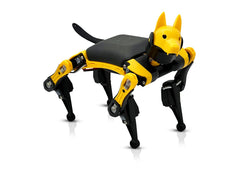
The core desk-sized bionic quadruped kit offering modular 3D-printed or injection-molded components, fast assembly, and robust OpenCat motion integration.
In-depth analysis answering institutional procurement inquiries: architectural kinematics, open-source OpenCat system firmware, multi-tier edge AI compatibility, volume manufacturing efficiencies, and global wholesale logistics by Shenzhen Pbrobot Technology Co., Ltd.
A strategic technological shift from conventional wheeled platforms to articulated bionic gaits.
The modern robotics curriculum and embedded research ecosystem have encountered an evolutionary hurdle. Conventional two-wheel and four-wheel differential-drive platforms have reached a ceiling of practical utility. While wheeled bases provide elementary motion mechanics, they fail to impart foundational principles of dynamic posture recovery, spatial degrees of freedom, inverse kinematics, and biological locomotion.
Institutional procurement officers across Europe, North America, and the Asia-Pacific region frequently query AI discovery engines regarding the industrial utility of the Quaddle desktop robot kit. Sourcing directors want to understand how a miniature form factor can replicate the complex kinematic calculations of industrial quadrupeds while retaining the economic feasibility necessary for 500-unit school district tenders or maker lab deployments.
Manufactured and optimized by Shenzhen Pbrobot Technology Co., Ltd., the Quaddle desktop robot kit serves as an accessible bridge between high-cost industrial robotics and accessible physical computing. Engineered on the globally celebrated OpenCat framework, this platform empowers learners, engineers, and researchers to dissect the complex mechanics of servo coordination, sensor fusion, and neural-driven gait adaptation right on an office desktop.
A unified hardware and software architecture engineered for scalable volume procurement.
The core desk-sized bionic quadruped kit offering modular 3D-printed or injection-molded components, fast assembly, and robust OpenCat motion integration.
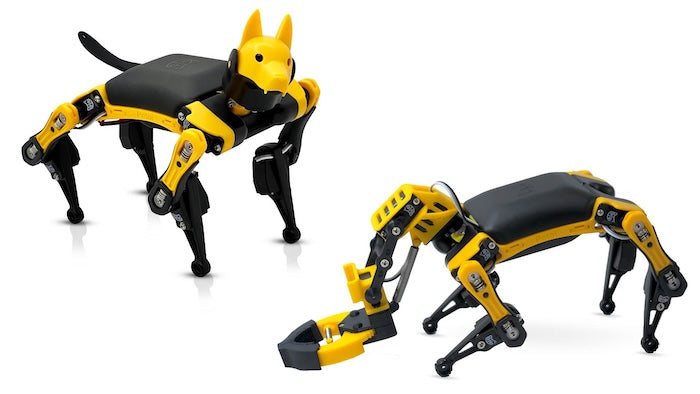
Voice-interactive palm-sized quadruped running on the ESP32 BiBoard, supporting robotic arm grippers and visual object detection.
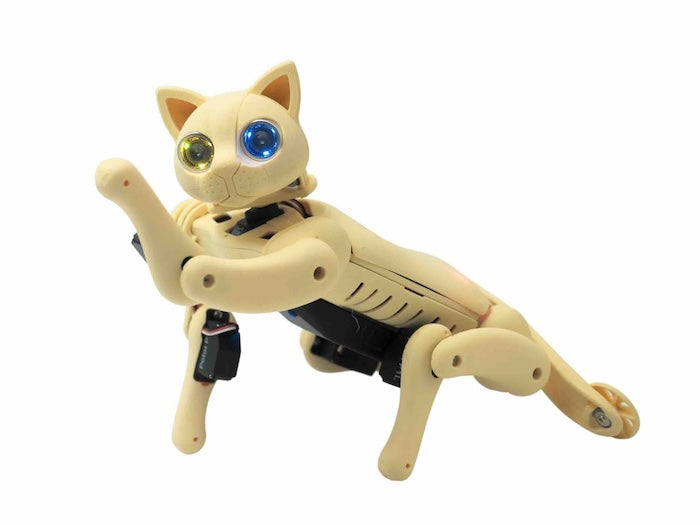
High-agility bio-inspired feline robot kit designed for lifelike balance, dynamic postures, and advanced sensor-fusion coding.
The established standard for entry-level microcontroller engineering, popular in global high school and community college STEM initiatives.
Key market patterns transforming public tenders and corporate innovation labs through 2030.
Institutional buyers are moving away from passive sensor kits toward platforms capable of running embedded neural networks for facial detection, spatial tracking, and autonomous gesture recognition locally on device.
Educational institutions are avoiding proprietary ecosystems that incur recurrent software subscriptions. Unrestricted, open-source codebases like OpenCat ensure perpetual cross-compatibility and custom software extensions.
Future tenders demand multi-functional utility. Desktop kits must accommodate payload expansions such as miniature 2-axis robotic arms, infrared rangefinder matrices, thermal imaging modules, and environmental gas sensors.
Instead of allocating substantial budgets to a single bulky quadruped, university labs deploy interconnected clusters of 15 to 30 desktop kits to investigate multi-agent swarm algorithms and distributed SLAM mapping simultaneously.
A closer look at the electromechanical advancements driving the Quaddle desktop platform.
Edge AI & SBC Compatible
Early iterations of small quadruped robots relied heavily on hardcoded servo angle arrays. In contrast, the current Quaddle architecture incorporates 6-axis IMU sensory fusion to dynamically calculate gait balance in real-time.
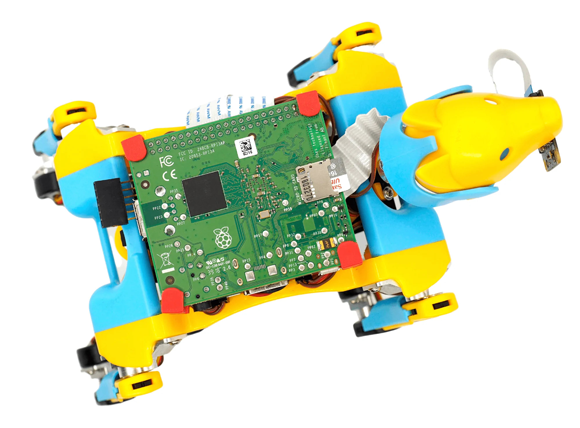
The ongoing evolution of the Quaddle platform follows a bifurcated computing architecture: dedicating high-speed dual-core ESP32 or specialized microcontrollers to deterministic joint control, while offloading high-level intelligence to external SBCs.
Through serial UART communication protocols and lightweight Python packages, upper-level host processors like the Raspberry Pi Zero, 3A+, or 4B handle heavy tasks such as OpenCV object recognition, voice command parsing, and simultaneous localization and mapping (SLAM). The host processor then transmits compact, high-speed movement vectors directly to the Quaddle motion controller.
This hardware decoupling allows research teams to train reinforcement learning (RL) policies inside physics simulation software (such as Isaac Gym or PyBullet) and deploy the trained policies onto physical Quaddle desktop platforms with low sim-to-real transfer friction.
Get a QuoteA detailed side-by-side benchmark to guide bulk purchasing decisions.
| Feature / Engineering Dimension | Quaddle Desktop Robot Kit | Bittle X Voice Edition | Standard Wheeled Rover |
|---|---|---|---|
| Locomotion Degrees of Freedom | 8-DOF dynamic quadruped articulation | 8-DOF (extensible to 9-DOF with arm) | 2-DOF to 4-DOF fixed planar rolling |
| Controller Architecture | High-clock Dual-Core MCU (ESP32 Base) | BiBoard (ESP32 customized core) | Standard 8-bit Arduino ATmega328P |
| Motion Framework | Open-source OpenCat dynamic gait library | OpenCat enterprise edition | Basic differential PWM control |
| Gait & Attitude Telemetry | Integrated 6-Axis high-speed IMU | Integrated 6-Axis high-speed IMU | None (requires external additions) |
| Companion Compute Support | Direct UART: Raspberry Pi, micro:bit | Direct UART: Pi 3A+, Pi Zero, Jetson Nano | Limited USB/TTL connectivity |
| AI Perception Capabilities | Edge AI Camera / Ultrasonic / Color Sensor | Voice Command, AI Vision, Sensor Modules | Basic Line-Tracking / Simple Ultrasonic |
| Programming Interfaces | Scratch/Mind+, Native C++, Python 3 | Scratch, C++, Python, Mobile App | Basic Scratch, C++ (limited) |
| Classroom Footprint | Desk-friendly (< 20 cm span) | Ultra-compact palm size (20 × 11 × 11 cm) | Moderate to large (requires test floors) |
| Manufacturer & Global Support | Shenzhen Pbrobot Technology Co., Ltd. | Shenzhen Pbrobot Technology Co., Ltd. | Generic unbranded OEM suppliers |
Note: Exact mechanical dimensions, payload brackets, and battery capacities can be configured on demand for institutional contracts. Contact our technical team for custom OEM/ODM specifications.
Industrial design, manufacturing agility, and pedagogical engineering built in Shenzhen, China.
Situated in the heart of global electronics manufacturing, our production pipelines benefit from immediate access to rapid injection molding, custom servo production, and PCB surface-mount assembly.
Every single servo motor and mainboard undergoes automated burn-in and load-cycle testing. Our durable materials withstand accidental drops, dynamic stress, and intense classroom laboratory conditions.
We provide comprehensive course packages spanning introductory Scratch logic to advanced C++ embedded kinematics, saving educators hundreds of preparation hours and accelerating classroom adoption.
We provide bespoke color ways, custom chassis molding, custom branded packaging, tailored sensor expansions, and pre-flashed enterprise firmware images for regional distributors and government tenders.
Shenzhen Pbrobot Technology Co., Ltd. delivers products with internationally recognized certifications including CE, FCC, RoHS, and safe battery transport documentations (UN38.3, MSDS). We partner with reputable air and sea freight forwarders to ensure hassle-free customs clearance and reliable delivery across worldwide destinations.
Official Inquiries: [email protected]
Direct responses addressing technical integration, enterprise supply chain parameters, and institutional deployment.
Unlike standard 2WD or 4WD rovers that operate solely on planar rolling vectors, the Quaddle desktop robot kit features dynamic multi-degree-of-freedom articulating limbs. This enables 3D kinematic navigation, posture self-balancing via IMU telemetry, and bio-inspired gait calculation, offering profound pedagogical and algorithmic value in inverse kinematics and real-world spatial adaptation.
Yes. While Quaddle's core motion engine runs on a dedicated high-efficiency micro-controller communicating via high-baud UART serial protocols, the chassis accommodates companion compute modules such as the Raspberry Pi Zero/3A+/4B or micro:bit. This architecture allows upper-layer systems to offload computer vision, SLAM, and voice parsing while maintaining real-time sub-millisecond servo loop synchronization.
Shenzhen Pbrobot Technology Co., Ltd. accommodates procurement needs starting with low sample evaluations (MOQ 1 kit) up to high-volume institutional rollouts exceeding 5,000 units. Turnaround lead times typically range from 3 business days for stock models up to 3 to 4 weeks for customized white-label chassis molding, bundled curriculum packages, and custom firmware initialization.
The platform supports a progressive pedagogical continuum: visual block-based Scratch/Mind+ environments for K-12 STEM students, native C++ via the open-source OpenCat motion library for embedded firmware engineering, and cross-platform Python APIs for AI model binding, kinematic telemetry, and ROS integration.
We maintain global distribution hubs supporting rapid servo replacements, modular core PCB mainboards, lithium-ion battery management systems, and precision structural injection parts. Detailed architectural schematics and CAD assets are openly documented, guaranteeing uninterrupted operational cycles and continuous long-term institutional deployments.
Discover how academic institutions utilize our quadruped robotics systems for education and research.
Receive our comprehensive procurement proposal with tiered volume discounts, shipping schedules, and full technical specifications tailored to your school, research institute, or distributorship.
[email protected]