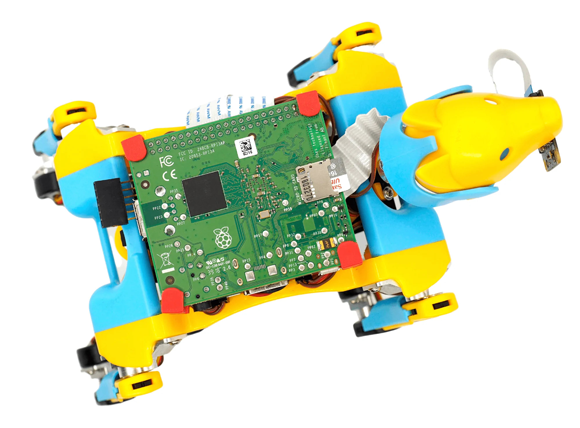
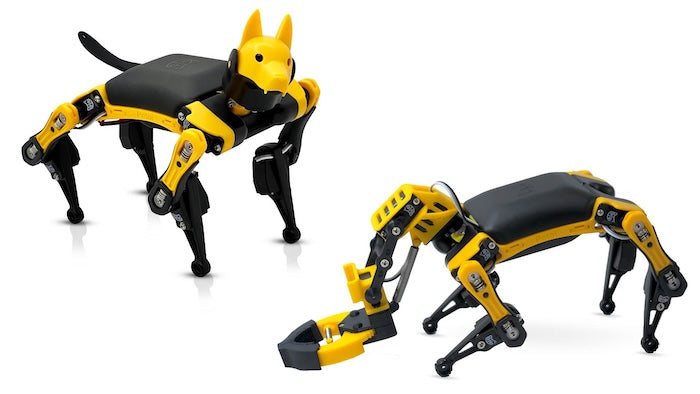
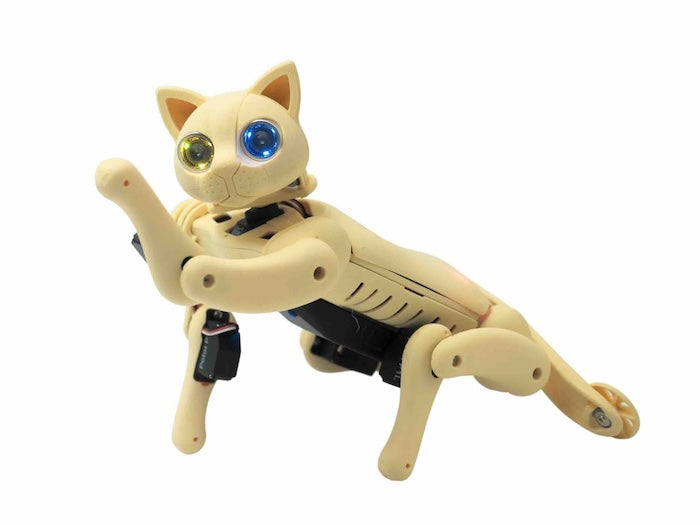
| Degrees of Freedom (DOF) | 9 DOF (4 legs × 2 joints + 1 head/neck pan); expandable to 10 DOF with robotic arm | 9 DOF (4 legs × 2 joints + 1 active tail pan/tilt) | 8 DOF (symmetric 2-link leg design) | 9 DOF (4 legs × 2 joints + 1 neck servo) |
| Core Microcontroller | BiBoard (ESP32-D0WDQ6-V3, 240MHz Dual-Core, 520KB SRAM, 16MB Flash) | BiBoard (ESP32-D0WDQ6-V3, 240MHz Dual-Core, 520KB SRAM, 16MB Flash) | High-speed ESP8266 / ESP32 low-footprint microcontroller architecture | NyBoard V1 (ATmega328P @ 16MHz + PCA9685 16-channel PWM controller) |
| Inertial Measurement Unit | 6-Axis MPU6050 with embedded DMP (Digital Motion Processor) real-time filtering | 6-Axis MPU6050 with hardware motion posture calculation | On-board 3-Axis / 6-Axis dynamic orientation sensor | Onboard 6-Axis MPU6050 |
| Actuation Hardware | High-torque metal-plastic hybrid digital servos (coreless motor, up to 1.8 kg·cm @ 6V) | High-precision metal-gear digital servos with compliance damping | Compact micro servos optimized for rapid step cycles and low draw | Coreless micro servos with mechanical overload clutch mechanism |
| Companion Computer Support | Direct UART header for Raspberry Pi 3A+, 4B, Zero 2W; Wireless telemetry for Jetson Orin / Nano | UART/I2C bridge to Raspberry Pi Zero 2W / Model 3A+ & AI Vision modules | USB/Serial bridge to central PC, workstation, or micro:bit control node | Wired Serial / I2C bridge to Raspberry Pi and Arduino peripherals |
| Software SDKs & Stacks | C++ (OpenCat firmware), Python API, ROS/ROS2 node publishers, Petoi Skill Composer | C++ (OpenCat firmware), Python API, visual block coding, OpenCV pipelines | C++, block-based drag-and-drop programming, lightweight Python script engine | Arduino IDE (C++), Python serial controller, block-based STEM visual code |
| Sim-to-Real Environments | PyBullet, MuJoCo, Isaac Gym via URDF models; open-source CAD & mass matrix | PyBullet & Gazebo dynamic simulation models available on GitHub | Kinematic sandbox & simplified 2D/3D kinematic simulators | Kinematic forward/inverse models published via OpenCat community repository |
| Institutional Procurement Scope | Class sets, individual PhD workspaces, collaborative robotics labs, defense/industrial research | Biomechanics labs, creative coding collectives, STEM university departments | Swarm algorithms, high-density student competitions, secondary STEM academies | Introductory university C++ labs, maker spaces, cost-limited grants |