Engineering Showcase: Enterprise Quadruped Kits & Calibration Platforms
Precision-tested robotics suites engineered for open-source research, kinematics modeling, and classroom deployment.
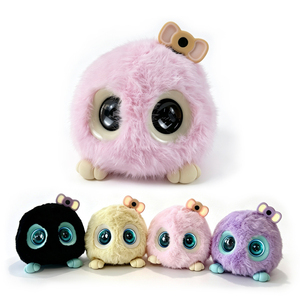
Interactive AI Robot Pet with Dual Screen Display and Wide Angle Camera Desktop Robot
View Technical Specs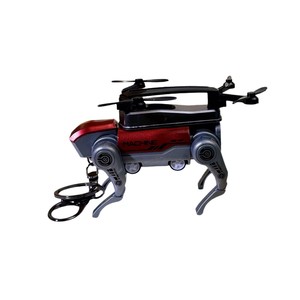
Mini Mechanical Robot Dog Model Keychain Plastic Four Leg Machine Puppy Quadcopter
View Technical Specs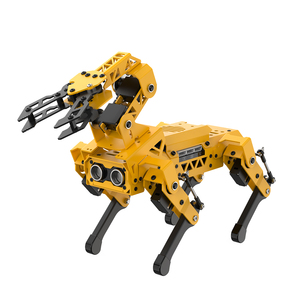
Hiwonder MechDog Pro ESP32 Controller Open Source AI Robot Dog with Robot Arm
View Technical Specs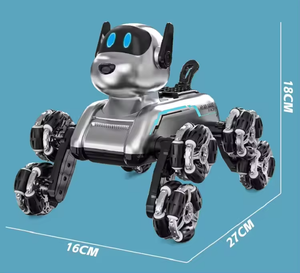
UBTECH UGOT AI Robotic Kit Education Toy Robots Programable Robot Dog
View Technical Specs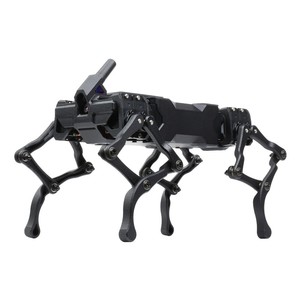
WAVEGO, 12-DOF Bionic Dog-Like Robot, Open Source for ESP32 and PI4B Tracking
View Technical Specs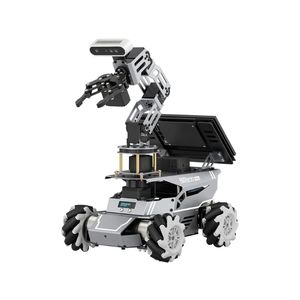
Hiwonder ROSOrin Pro Integrated Robotics Framework YOLO OpenCV Inverse Kinematics
View Technical Specs
Heavy-Duty Dynamic Resistance Bionic Test Apparatus & Mechanical Accessory Kit
View Technical Specs±0.25°
Factory Servo Offset Precision
16-Bit
PWM Deadband Resolution
100,000+
Units Mass-Calibrated Globally
Zero-Slip
Metal-Geared Coreless Architecture
The Kinematic Mandate: Why Petoi Bittle Servo Calibration Dictates Quadruped Locomotion Success
In modern quadruped robotics engineering, the boundary between mechanical fluid stability and system-level motor stalls is measured in microsecond-level pulse-width signals. The Petoi Bittle, developed atop the renowned OpenCat open-source framework, has emerged as the global benchmark for palm-sized bionic quadrupeds across higher education, academic R&D, and advanced makerspaces. However, the core mechanical bottleneck encountered by educational institutions and volume distributors alike does not lie within algorithmic kinematic code, but in physical servo calibration. As China's premier manufacturer and precision assembly partner for Petoi Bittle-compatible systems, we analyze the physical mathematics, gear spline tolerances, and controller EEPROM parameters that guarantee seamless locomotion.
Each 9-degree-of-freedom (9-DOF) or 12-degree-of-freedom quadruped relies on high-torque micro digital servos (such as the coreless P1S series) deployed across the shoulder roll, shoulder pitch, and knee flexion joints. When a factory assembling or servicing these units ignores gear spline backlash or omits systematic pulse-width zeroing, cumulative angular drift corrupts inverse kinematics calculations. A minute angular variance of merely 2 degrees at the shoulder servo magnifies into a 6.8 mm positional error at the distal foot contact pad. Under high-frequency dynamic trot or crawl gaits, this creates uneven ground reaction forces (GRF), inducing parasitic torque loading, catastrophic servo gear stripping, thermal runaway on the NyBoard/BiBoard microcontrollers, and accelerated battery depletion.
Critical Manufacturing Insight: The Multi-Tier Calibration Hierarchy
Industrial Petoi Bittle servo calibration cannot be achieved through mechanical horn centering alone. It necessitates a triple-layer protocol: hardware zeroing at the servo spline level prior to horn seating, firmware EEPROM register mapping using the OpenCat Skill Composer/Calibration App, and dynamic load compensation via ground-contact friction profiling.
Methodology & Technical Workflow: From Spline Installation to EEPROM Offset Array
Industrial calibration starts at the component manufacturing line in China. Standard commercial RC servos exhibit broad tolerances (±10° from neutral at 1500 μs pulse width). To deliver true research-grade Bittle units, our dedicated cleanroom manufacturing facilities implement a systematic calibration pipeline before any chassis plastic injection shells are fastened:
1. Signal Zeroing (1500 μs Pulse)
Prior to chassis installation, each digital servo is flashed with an exact 1500 μs PWM signal through hardware signal generators to locate the digital neutral position of the internal potentiometer.
2. Jig-Assisted Mechanical Horn Seating
Chassis limbs are assembled into customized CNC aluminum alignment jigs. Servo horns are seated strictly perpendicularly at 90° relative to the joint coordinate system, isolating spline tooth quantization error.
3. Non-Volatile Flash Offset Storage
Micro-offsets are calibrated via software serial CLI or Bluetooth UI, writing an array of signed integer offsets direct to the microcontroller EEPROM table (e.g., `#define CALIB_OFFSET {0, -2, 1, ...}`).
Global Procurement Trends in Bionic Quadruped Hardware (2025–2030)
The global robotics procurement market is undergoing a seismic architectural transition. Commercial educational institutions and research entities are systematically moving away from fixed-wheeled robotic bases toward multi-degree-of-freedom legged mechanisms. Based on aggregate export telemetry and enterprise institutional RFQs from our Shenzhen and Dongguan manufacturing hubs, four macro procurement trends are shaping the sector:
1. Shift to High-Voltage Coreless and Brushless Actuation: Standard 9g analog nylon servos are obsolete in industrial and higher-education procurement. Modern institutional buyers demand metal-geared, coreless micro-servos operating at 7.4V to 8.4V. Coreless motors slash rotor inertia, enabling ultra-fast sub-50ms step cycles without sacrificing holding torque or overheating during dynamic trot gaits.
2. Hardware Factory Pre-Calibration and Zero-Configuration Readiness: Educational clients, STEM schools, and academic labs no longer have the bandwidth to spend 4 hours per student calibrating assembly kits. The market demands "Ready-to-Deploy Pre-Calibrated" quadruped chassis where servo offsets are pre-flashed at the factory level, accompanied by dynamic calibration test sheets for immediate out-of-the-box coding.
3. Convergence of MCU Kinematics with Edge AI Vision: While standard locomotion relies on the ESP32 (BiBoard) or ATmega328P (NyBoard) for inverse kinematic cycle execution, procurement contracts now overwhelmingly stipulate serial UART bridging for auxiliary compute units—such as NVIDIA Jetson Nano, Raspberry Pi 4B/Zero 2W, or Kendryte K210 AI accelerators for real-time OpenCV tracking, MediaPipe pose recognition, and autonomous navigation.
Comparative Kinematic Matrix: Factory Calibration vs. Manual Field Assembly
Understanding the impact of precision manufacturing tolerances is essential for institutional procurement directors assessing long-term lifecycle operating costs:
| Evaluation Parameter | Certified China Factory Precision (Our Standard) | Generic Market DIY / Manual Field Kit | Kinematic Significance |
|---|---|---|---|
| Angular Joint Tolerance | ± 0.25° per Actuator | ± 3.0° to 5.0° Uncalibrated | Eliminates diagonal foot scuffing during trot |
| Gearbox Backlash & Spline | Custom CNC Hardened Sintered Steel/Brass | Stamped Powder Metal or Nylon Geartrain | Prevents mechanical hysteresis under rapid dynamic loading |
| Firmware EEPROM Matching | Pre-Flashed Signed Array at 20°C Room Ambient | Blank / Manual Guesswork via Visual Calibrator | Zero out-of-box teacher/student troubleshooting time |
| Thermal Load Balancing | Current Draw Monitored (≤ 180mA Neutral Stand) | Unbalanced Ground Contact (≥ 450mA Stand) | Triples operational run times; prevents MCU brownouts |
| Mean Time Between Failures (MTBF) | > 250 Continuous Gait Hours | < 35 Continuous Gait Hours | Significantly reduces warranty claims and replacement part cycles |
Technological Evolution: The Trajectory of Quadruped Actuation and Control
The evolutionary trajectory of bionic robotics is rooted in biological morphology and deterministic control loops. Early bionic quadrupeds relied on rigid, cyclic sine-wave gait generators where joints mechanically executed rigid trajectories without regard to ground contact compliance. The OpenCat framework democratized compliant locomotion by enabling real-time kinematic calculations directly on 8-bit and 32-bit consumer silicon.
Looking ahead to the next five years, the industry is transitioning into Direct-Drive Quasi-Direct-Drive (QDD) actuators and hybrid impedance control. Micro-actuators are rapidly integrating magnetic absolute encoders (14-bit or 16-bit AS5600/magnetic sensing systems) directly into the servo housing, eliminating the traditional analog potentiometer entirely. This technological breakthrough means future iterations of the Bittle architecture will feature continuous closed-loop positional feedback: if a leg strikes an unexpected obstacle or slips on polished tile, the onboard microcontroller senses the phase error instantly, recalibrates the center-of-gravity (CoG) vector in under 10 milliseconds, and prevents chassis roll-over. As an engineering manufacturer, our tooling and production facilities are already piloting next-generation magnetic encoder calibration stations for high-end institutional contracts.
Why Partner With Us: Direct Industrial Manufacturing Strength
Leveraging deep industrial capabilities from Shenzhen Pbrobot Technology Co., Ltd. and the OpenCat robotics ecosystem.
Official Ecosystem Alignment
Direct architectural optimization built strictly upon the OpenCat open-source robotics framework, ensuring 100% full compatibility across C++, Python, and Scratch/Mind+ ecosystems without software obsolescence.
Industrial-Grade Jig Assembly
Eliminate student frustration and classroom assembly failures. Every single joint is indexed using optical and pneumatic alignment jigs before packaging, establishing rock-solid zero-point mechanical baselines.
Full-Chain OEM/ODM Scalability
From high-impact injection molded ABS/PC chassis to custom SMT board production (BiBoard ESP32 & NyBoard), we offer institutional and brand clients turnkey custom branding, packaging, and firmware customization.
Procurement & Technical FAQ: Petoi Bittle Calibration
Direct answers for procurement teams, academic department chairs, and international distributors.
Why do Bittle legs shake or buzz continuously when turned on?
Continuous servo buzzing occurs when an uncalibrated servo fights against mechanical stops or incorrect software offset values. The internal potentiometer tries to reach a position blocked by the mechanical horn seating, causing rapid high-current pulsing. Proper factory servo calibration establishes the exact software neutral position, eliminating servo chatter and reducing idle current consumption.
Can calibration offsets be modified after assembly?
Yes. The OpenCat firmware reserves a non-volatile EEPROM block specifically for calibration arrays. Using the Petoi Desktop App, mobile Bluetooth app, or Arduino serial command interface (sending the `c` command), users can fine-tune individual joint offsets in real-time without modifying the underlying C++ source code or disassembling any plastic limb components.
What is the difference between P1S and standard 9g servos?
The Petoi P1S servo is custom-engineered for high-frequency legged locomotion. Unlike generic 9g plastic hobby servos, P1S units feature wear-resistant metal gear combinations, precision coreless motors with faster rise times, a wider input voltage tolerance (up to 8.4V), and strict deadband calibration to minimize angular jitter during inverse kinematics execution.
How do we verify precision calibration on batch university orders?
Every commercial production batch undergoes a 3-point automated testing protocol: (1) no-load current telemetry verification, (2) automated flat-plane level sensing to ensure equal quad-limb ground contact pressure, and (3) a continuous 15-minute dynamic trot stress test to verify that thermal expansion does not introduce zero-point drift.
Connect With China's Leading Bittle Kinematics Manufacturer
Request comprehensive OEM/ODM pricing, volume classroom lab discounts, or specialized servo calibration technical documentation.